Day-to-Night Translation using CycleGAN
Method Overview
Abstract
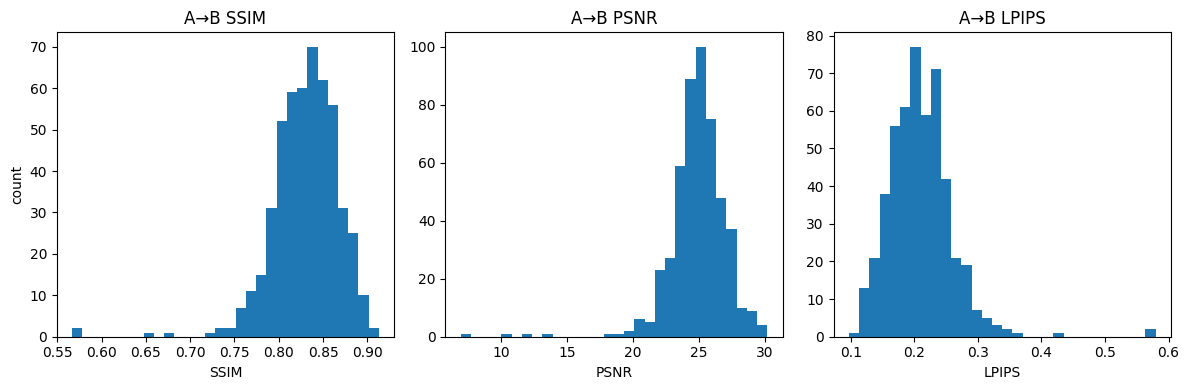
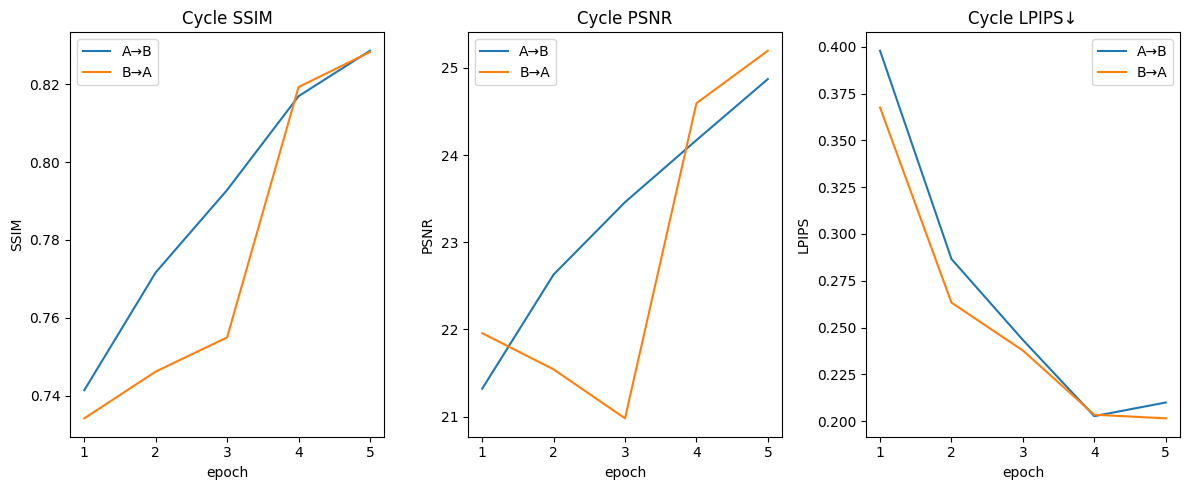
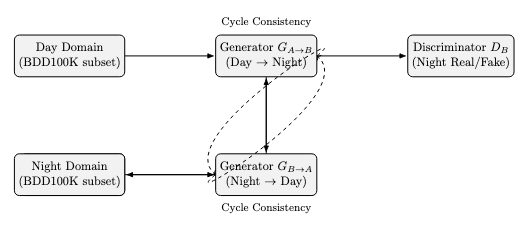
We study unpaired image-to-image translation for converting daytime driving scenes into nighttime equivalents using CycleGAN. The model learns mappings between Day↔Night without aligned pairs by combining adversarial training with cycle-consistency and identity losses. We report distributions of SSIM/PSNR/LPIPS and their trends across epochs, and show qualitative results for both Day→Night and Night→Day mappings.
Visual Comparisons
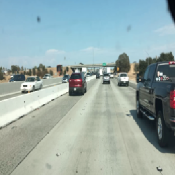
Day (Input)
Night (Generated)
Night (Input)
Day (Generated)
Results